
The OEMNex Sensing Engine
Sensing architecture
ExploreInspection systems must detect the defects and conditions that matter in their operating environment. Combining suitable sensing with artificial intelligence (AI)-supported assessment can help quality teams route findings into reviewed workflows, retain traceable records, and focus attention on uncertain or potentially nonconforming parts.
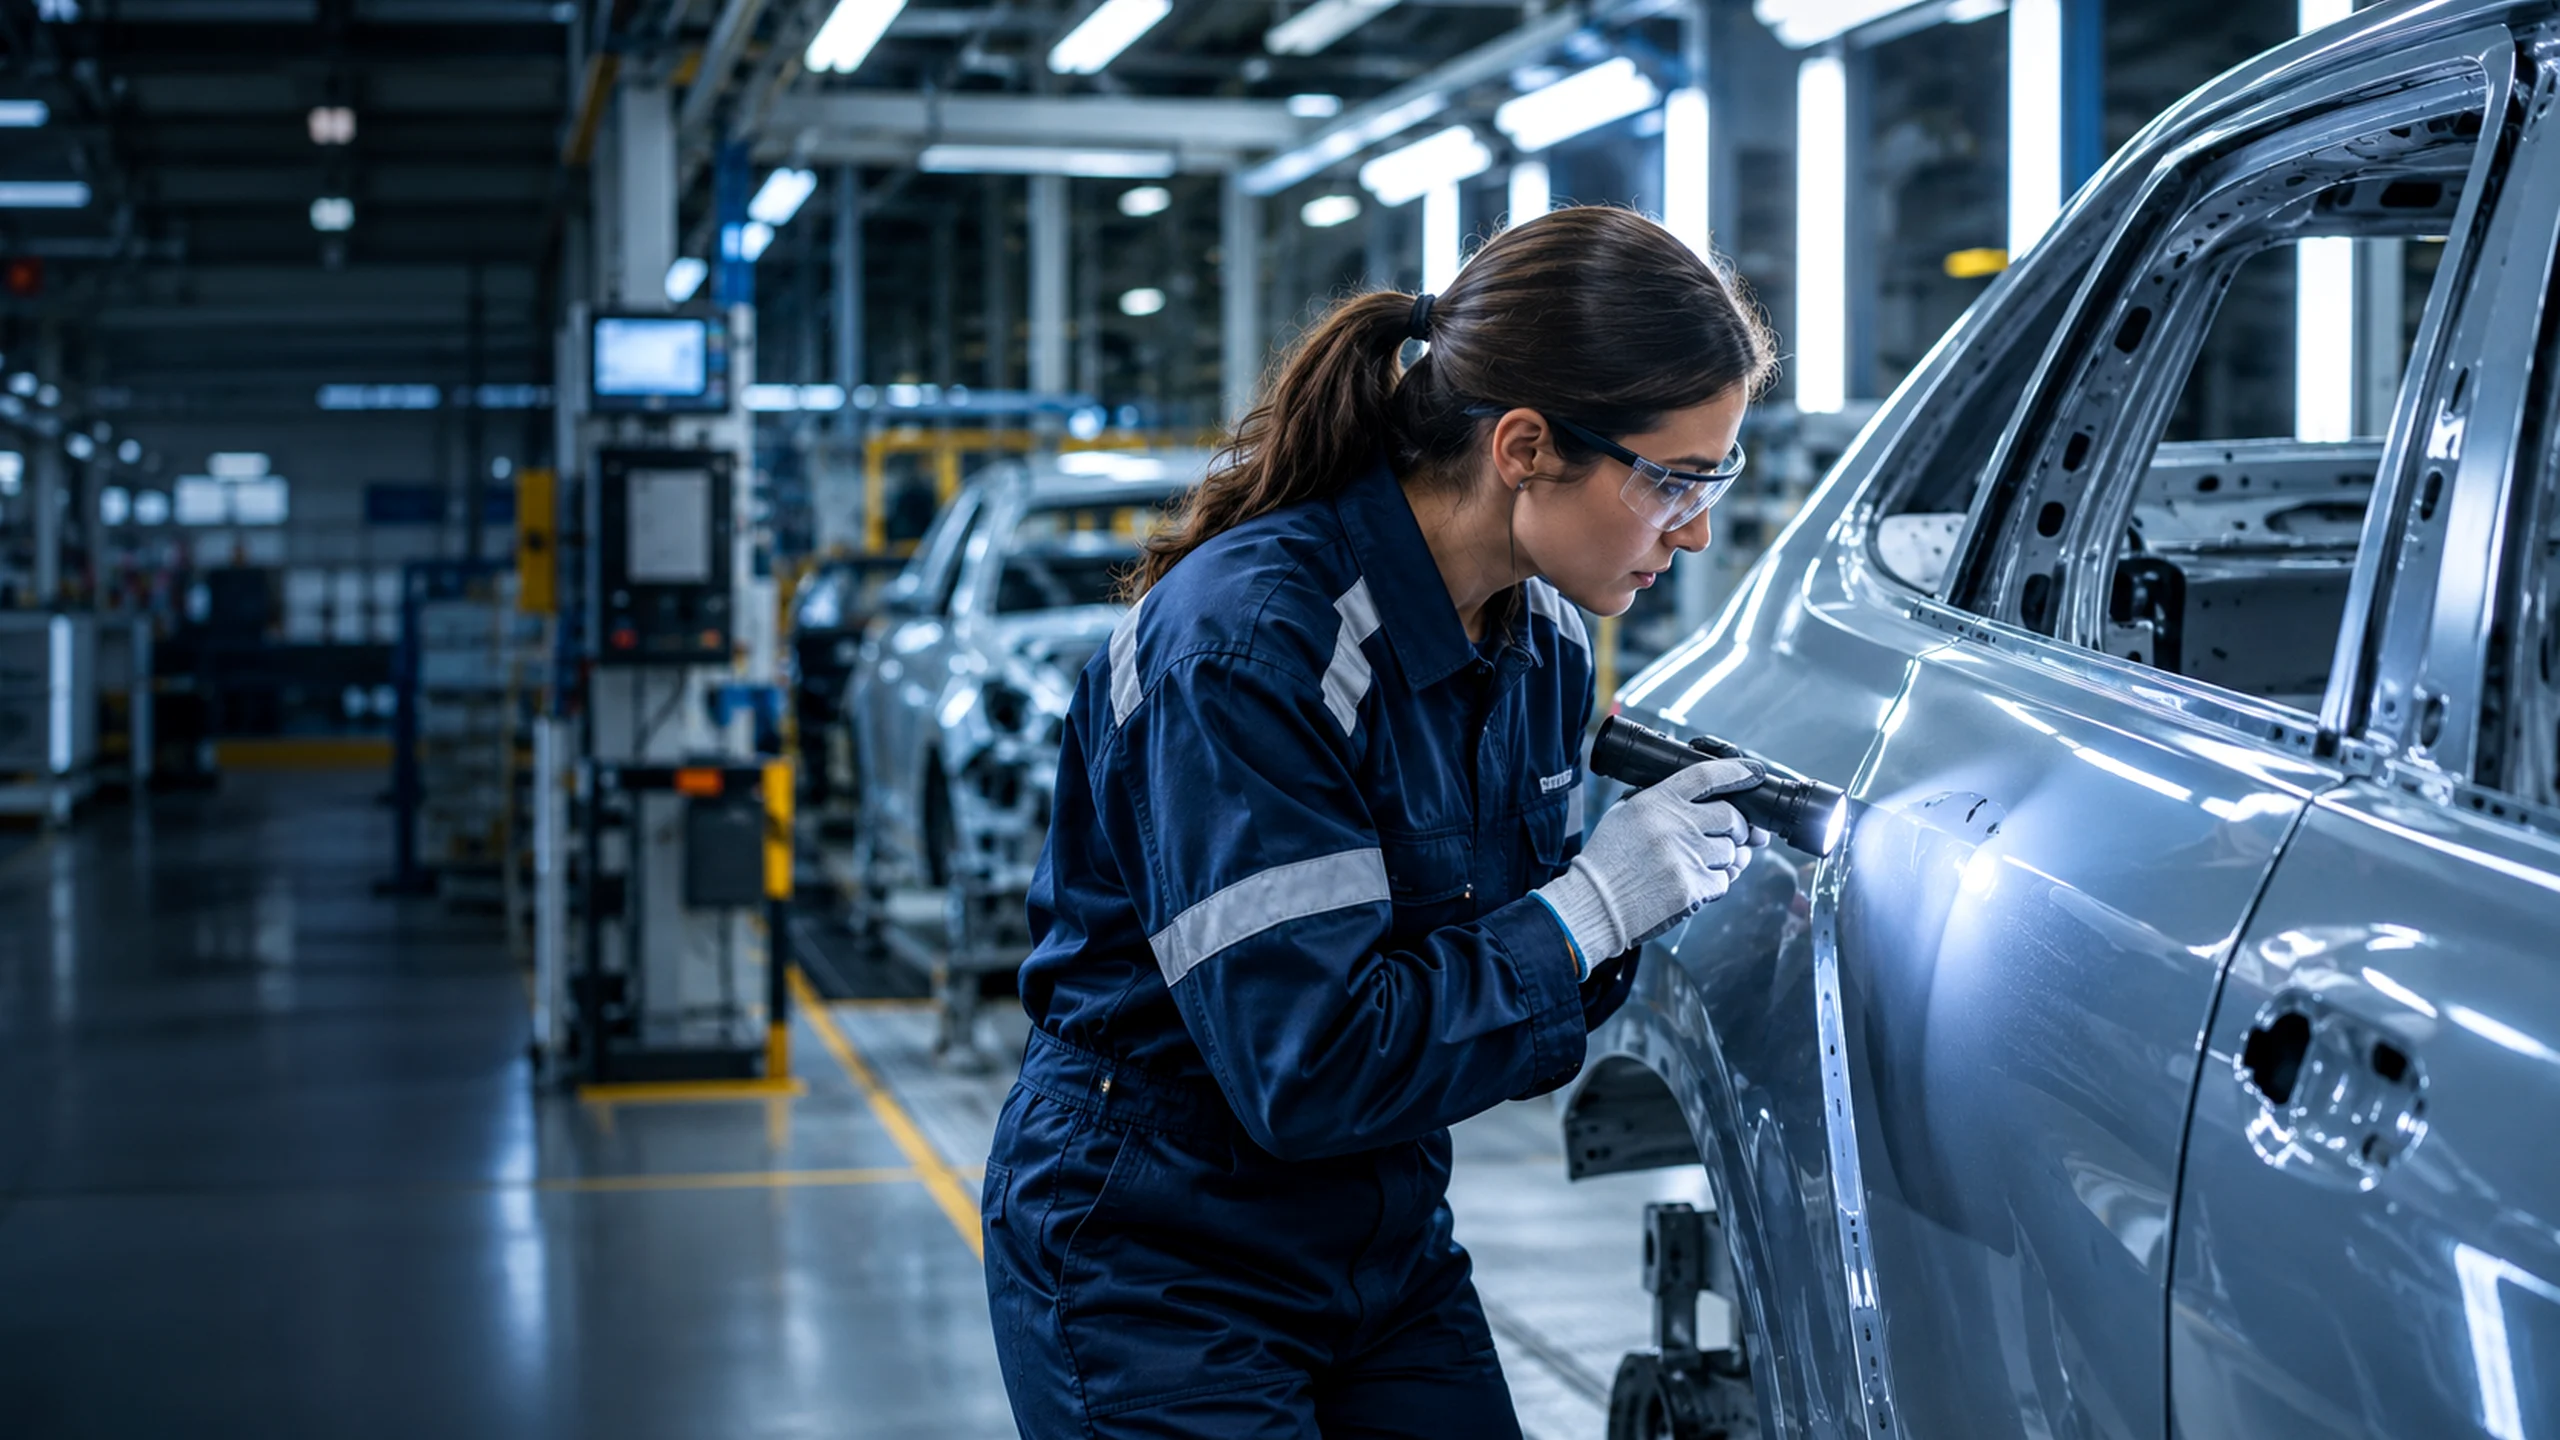
For original equipment manufacturer (OEM) vehicle production, inspection requirements vary by component, process stage, and acceptance criteria. A surface review of a painted body panel has different data and lighting needs from checking whether a connector is present, verifying a machined component’s dimensions, or reviewing a weld. An effective approach starts with a clearly defined inspection task, not with a model or sensor chosen in isolation.
Begin by identifying the part or assembly, the defect classes of concern, the applicable acceptance criteria, and the point in the production workflow where the inspection takes place. Examples may include surface scratches or dents on body panels, incomplete or misplaced components, dimensional variation in machined parts, or visible issues around joints and fasteners. The inspection specification should also account for part variation, line speed, access, lighting, vibration, contamination, and the consequences of a missed defect.
Quality engineers should agree on what counts as acceptable, nonconforming, and uncertain before collecting evaluation data. If a defect requires expert judgment, preserve that review step rather than forcing every observation into a binary pass-or-fail result.
The sensing method should match the physical property being inspected. Industrial cameras and controlled lighting can support visual checks of surfaces, assembly presence, orientation, and visible damage. Thermal, acoustic, dimensional, or other sensor inputs may be relevant when the inspection question cannot be answered reliably from ordinary images alone. Sensor selection should reflect the target defect, measurement limits, capture geometry, cycle time, and conditions at the inspection station.
Each captured observation should retain useful context, including part or vehicle identity where available, timestamp, inspection station, operating condition, sensor configuration, and data-quality status. Image blur, glare, occlusion, poor focus, sensor drift, missing records, and inconsistent part presentation can affect the reliability of downstream assessment. These conditions should be represented in the test data rather than removed from evaluation without explanation.
AI-supported assessment should be evaluated against labeled examples that represent both normal production variation and the defects the inspection is expected to detect. Labels should be reviewed by qualified personnel, with the labeling rules and disagreements documented. Keep development data separate from final evaluation data, and avoid allowing near-duplicate images of the same part or production event to make the test appear stronger than it is.
Review false positives, which send acceptable parts for unnecessary follow-up, alongside missed defects and false accepts, where a nonconforming part is classified as acceptable. False rejects can increase rework and inspection workload; missed defects can allow quality issues to move downstream. Report performance by defect class and relevant operating condition, not only as a single aggregate accuracy figure. Where the system is uncertain or the input is outside the evaluated conditions, route the result for additional inspection or human review.
An inspection result is useful when the next step is defined. Depending on the plant’s approved procedures, a finding may create a review task, request reinspection, flag a part for quarantine, or pass a decision to a validated sorting interface. Any interface to manufacturing execution systems, quality management applications, programmable controllers, or material-handling equipment must be assessed for data mapping, permissions, timing, and failure behavior before use.
Keep the observation, model assessment, reviewer decision, and resulting action as distinct records. A model output or software acknowledgment does not by itself confirm that a physical action occurred. Where sorting or other equipment action is considered, use an authorized control path and verify the resulting part state independently. Uncertain, stale, or incomplete observations should not silently trigger an irreversible decision.
A practical evaluation starts with a documented baseline inspection process and a set of labeled test cases. Include representative production variation, rare but important defect types, changes in lighting or part presentation, missing observations, and ambiguous cases. Test with real images and site-specific conditions before making field-performance claims. Synthetic images can help explore scenarios, but they must be labeled as synthetic and cannot replace evaluation on representative real production data.
Compare results with the current inspection method using the same defined test conditions where practical. Report denominators, exclusions, test-set composition, and known limitations. Detection performance alone does not establish lower scrap, less rework, or improved throughput; those outcomes require separate evidence from a workflow evaluation or a controlled pilot.
A focused pilot should target one inspection task with clear acceptance criteria, available reference labels, and an agreed response when the result is uncertain. Confirm access to representative parts and images, involvement from quality and manufacturing engineering, and a safe method for comparing candidate results with the existing process. Define success measures before testing and record where human review remains necessary.
OEMNex can discuss how Physical AI and Artificial Intelligence of Things (AIoT) concepts may fit a defined OEM vehicle inspection workflow, including sensing inputs, decision outputs, integration dependencies, and verification needs. The appropriate design and its readiness must be assessed against the target facility and available evidence; no particular connector, deployment configuration, or inspection performance is implied by this page.
Bring a description of the target part, defect types, acceptance criteria, existing inspection method, available reference data, and the action taken when a defect is found. These details help establish whether AI-supported inspection is appropriate and what a fair evaluation would need to measure.
Use these links to explore adjacent sensing, decision, integration, and research topics.